Access is difficult.
Hazardous terrain, restricted sites, and hard-to-reach infrastructure make capture costly and repeat visits difficult.
INTELLIGENCE, BEYOND CONTROLLED CONDITIONS.
A world model that understands humans, 3D space, and what happens next.
Enter the real world ↗People move. Conditions change.
The next moment is never guaranteed.
FOURDEE WORLD is building a single, shared 4D world model for humans and robots. A model that understands the geometry of a place, the people within it, and how the scene evolves.
A robot must understand what to do when the world changes.
Explore the world model ↗Geometry, scale, objects.
Motion, dynamics, time.
Shape, movement, interaction.
A shared foundation for action.
Our focus is the physical economy’s
most demanding environments.
The places where intelligence matters most.
Difficult terrain. Limited visibility. Conditions that won’t stand still. Our focus: world intelligence for perimeter observation and robotic navigation in uncertain environments.
Environmental inspection, cleanup, and restoration.
The same intelligence, working for a world worth protecting.
THE REAL-WORLD DATA CHALLENGE
Collecting data where intelligence matters is anything but trivial.
Access is limited. Observations are incomplete. The world keeps changing. Our approach builds on sample-efficient, compute-efficient research that learns from sparse, unconstrained observations.
Hazardous terrain, restricted sites, and hard-to-reach infrastructure make capture costly and repeat visits difficult.
Weather, lighting, geometry, and human movement vary together. Every observation captures only part of the world.
Consequential events may appear infrequently and can be unsafe or impractical to recreate for a dataset.
Build from evidence. Predict possibilities.
Ground in reality. Verify against constraints.
THE WORLD MODEL / INTERACTIVE EXPLORER
Space is only part of the story. A world model connects people and places with how they change over time.
Humans and physical space, modeled together.
Shape and motion across a changing scene.
Explore trajectories, constraints, and uncertainty.
03 / THE INTELLIGENCE STACK
Four connected pillars turn a model of the world
into a foundation for grounded robotic action.
Create executable 4D worlds with geometry, dynamics, objects, agents, and physics. A world has to do more than look convincing. It needs scale, causality, and consistency.
CONSTRUCT → EVOLVE → CHECK CONSISTENCY
04 / THE FOUNDATION
Better world models begin with
a precise understanding of humans
and the spaces around them.
Research in sub-centimeter human shape and kinematics — connecting physical form with movement.
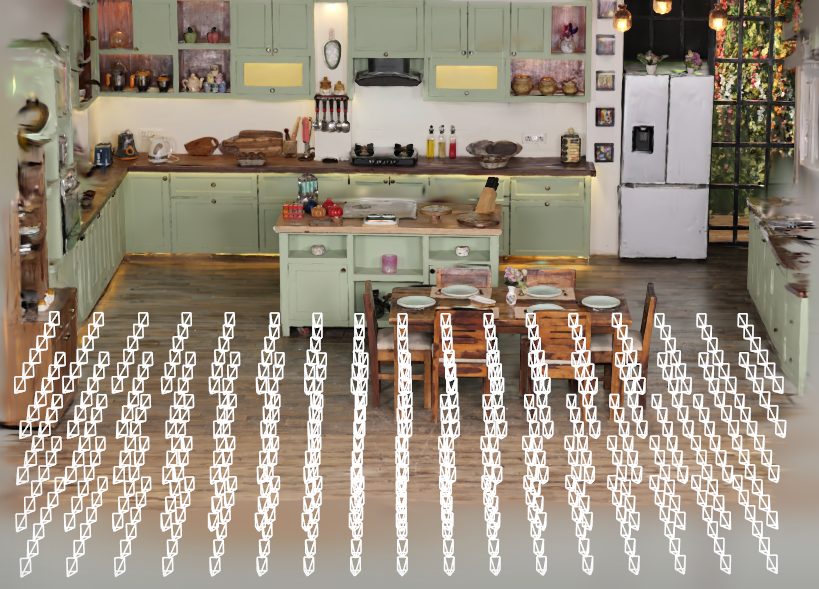 Scene reconstruction · FOURDEE WORLD
A mathematically precise, 1:1 coordinate framework for physics and navigation. Capture, reconstruct, and verify.
We are builders who know how to make things work in unconstrained environments.
Our work begins with the world as it is: sparse observations, imperfect inputs, moving people, and spaces we don’t control. Learning intelligence from these conditions has always been central to our work.
That experience shapes FOURDEE WORLD. We connect rigorous research with the physical understanding robots need in changing environments.
Our team is led by Aayush Bansal, whose doctoral research at Carnegie Mellon University’s Robotics Institute explored learning the 4D audiovisual world from sparse, unconstrained real-world samples.
His work spans robotics, generative AI, and spatial AI, from robot localization to image and video synthesis and 3D/4D reconstruction. He develops sample-efficient and compute-efficient approaches that learn from sparse observations, with a consistent focus on making research work in the real world.
Explore his background ↗Making robots truly capable where intelligence matters.
THE NEXT FRONTIER IS THE REAL WORLD.
A tightly scoped task can make an impressive demo. We’re building world intelligence for the harder challenge: environments that change, situations that surprise, and decisions that matter.
Start a conversation ↗